


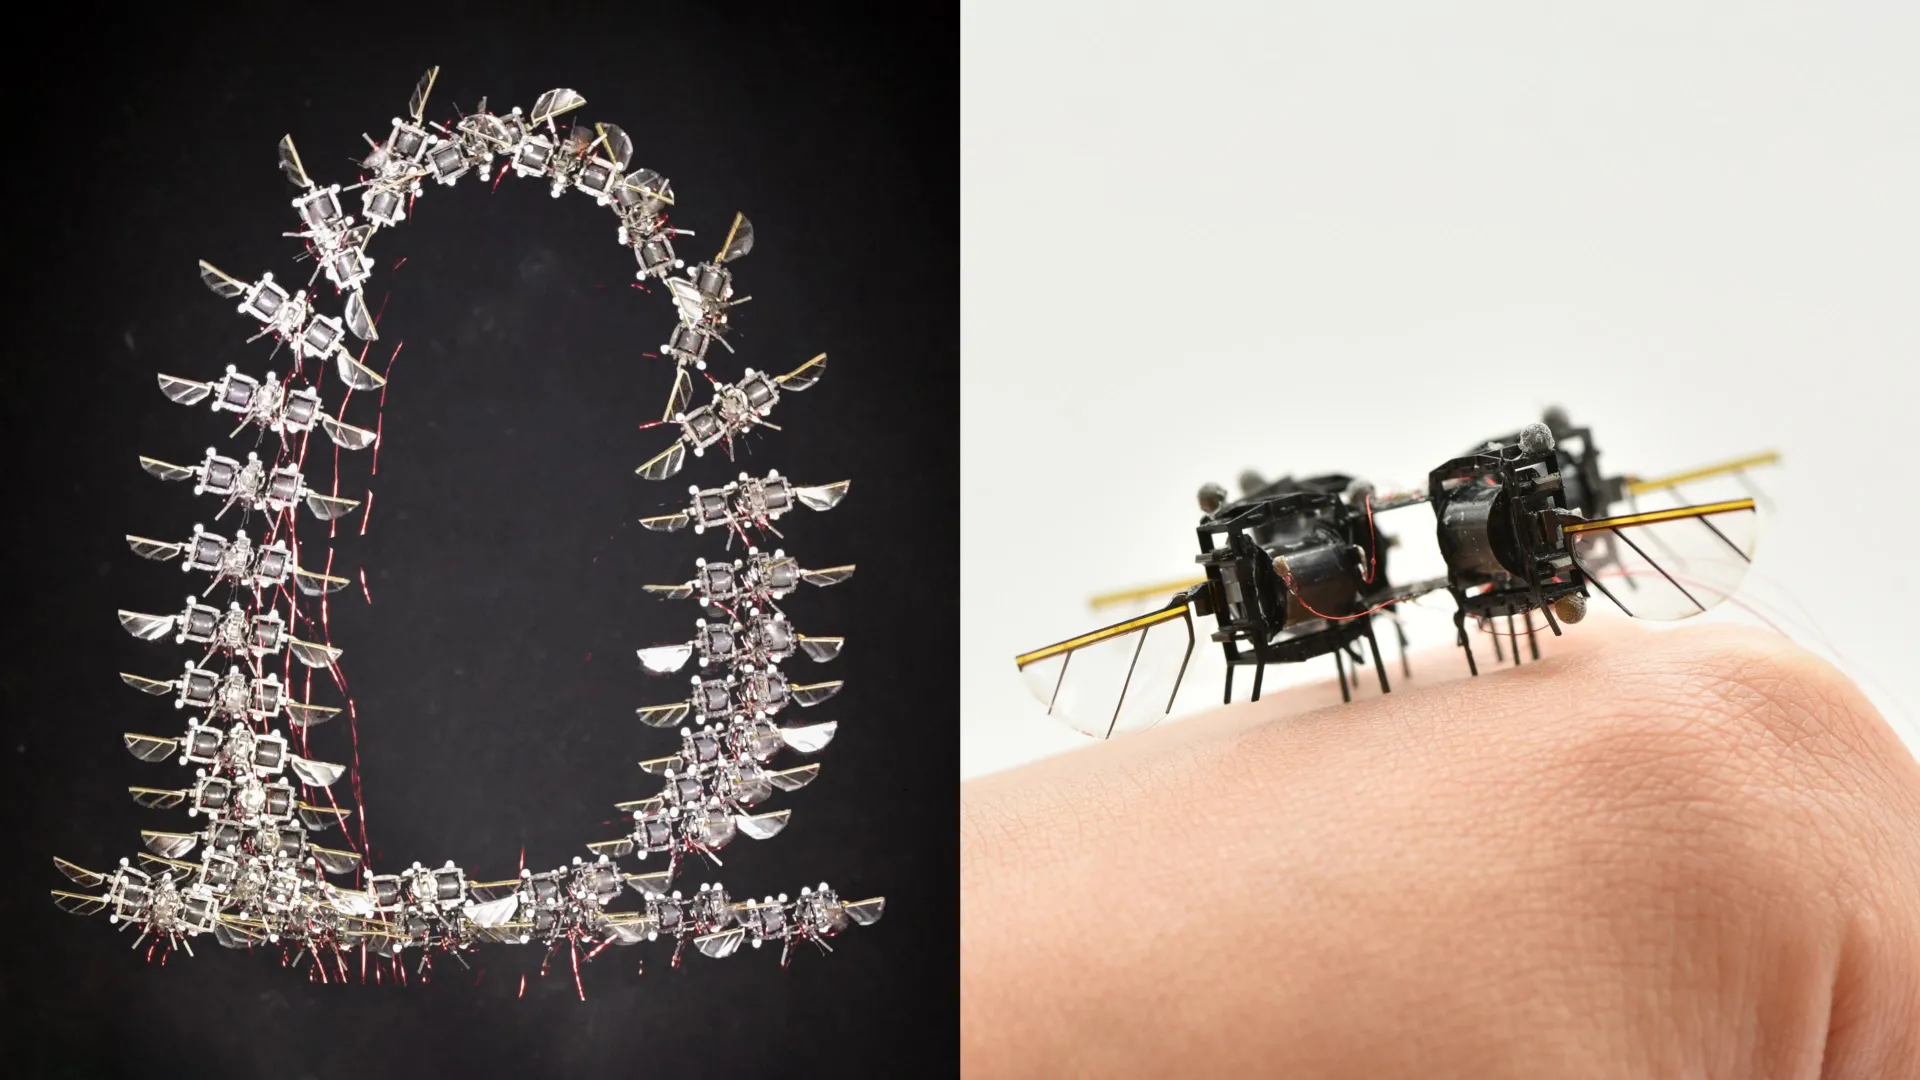
Tiny flying robots may one day help rescuers search for people trapped beneath collapsed buildings after earthquakes. Because of their small size, these robotic insects could potentially move through narrow spaces that larger drones cannot enter while avoiding walls, debris, and falling objects.
Until recently, however, aerial microrobots have been far less nimble than the insects that inspired them. They typically moved slowly and followed relatively simple flight paths.
Researchers at MIT have now demonstrated a new approach that gives an insect-scale flying robot much greater speed and agility. The team developed an AI-based controller that allows the robotic bug to perform demanding aerial maneuvers, including repeated body flips.
Using a two-part control system designed to balance performance with computational efficiency, the researchers increased the robot’s speed by about 450 percent and its acceleration by about 250 percent compared with their previous best results.
The robot was agile enough to complete 10 consecutive somersaults in 11 seconds, even while wind disturbances tried to knock it away from its intended path.
“We want to be able to use these robots in scenarios that more traditional quadcopter robots would have trouble flying into, but that insects could navigate. Now, with our bioinspired control framework, the flight performance of our robot is comparable to insects in terms of speed, acceleration, and the pitching angle. This is quite an exciting step toward that future goal,” says Kevin Chen, an associate professor in the Department of Electrical Engineering and Computer Science (EECS), head of the Soft and Micro Robotics Laboratory within the Research Laboratory of Electronics (RLE), and co-senior author of a paper on the robot.
Chen is joined on the paper by co-lead authors Yi-Hsuan Hsiao, an EECS MIT graduate student; Andrea Tagliabue PhD ’24; and Owen Matteson, a graduate student in the Department of Aeronautics and Astronautics (AeroAstro); as well as EECS graduate student Suhan Kim; Tong Zhao MEng ’23; and co-senior author Jonathan P. How, the Ford Professor of Engineering in the Department of Aeronautics and Astronautics and a principal investigator in the Laboratory for Information and Decision Systems (LIDS). The research was published in Science Advances.
AI Gives the Robot a Smarter Flight Controller
Chen’s group has spent more than five years developing robotic insects.
The team recently created a more durable version of their tiny robot, which is about the size of a microcassette and weighs less than a paperclip. This newer design has larger flapping wings that support more agile flight. The wings are driven by soft artificial muscles that contract rapidly enough to produce extremely fast wingbeats.
The physical design had improved, but the robot’s controller remained a major limitation. This controller acts as the robot’s “brain,” determining where the robot is and deciding how it should move. In earlier versions, a human had to tune the controller by hand.
For the robot to fly with the speed and aggressiveness of a real insect, the researchers needed a system that could handle uncertainty while rapidly solving complex control problems.
A controller powerful enough to do that would normally demand too much computation to operate in real time, especially because the aerodynamics of such a lightweight flying machine are highly complex.
To solve this problem, Chen’s group collaborated with How’s team to develop a two-step AI-driven control system. The design combines the robustness needed for difficult, high-speed maneuvers with enough computational efficiency to work in real time.
“The hardware advances pushed the controller so there was more we could do on the software side, but at the same time, as the controller developed, there was more they could do with the hardware. As Kevin’s team demonstrates new capabilities, we demonstrate that we can utilize them,” How says.
Teaching a Tiny Robot to Plan Difficult Maneuvers
The first part of the system uses what is known as a model-predictive controller. This type of controller relies on a dynamic mathematical model to predict how the robot will behave and determine the best sequence of actions for safely following a desired flight path.
Although this method requires substantial computing power, it can plan difficult movements such as aerial flips, sharp turns, and aggressive changes in body angle. The planner also takes into account limits on the amount of force and torque the robot can produce, helping it avoid movements that could lead to a crash.
Repeated flips are particularly challenging. To perform one somersault after another, the robot must slow down in exactly the right way so that it begins each new flip under the proper conditions.
“If small errors creep in, and you try to repeat that flip 10 times with those small errors, the robot will just crash. We need to have robust flight control,” How says.
The researchers then used this expert planner to train a “policy” built on a deep-learning model through a process called imitation learning. The policy serves as the robot’s real-time decision-making system, determining how and where it should fly.
In effect, imitation learning allows the team to capture the behavior of the more computationally demanding controller in a faster AI model that can operate quickly enough for real-time flight.
A major part of the challenge was generating enough useful training data to teach the policy how to handle aggressive maneuvers without creating an unnecessarily large data set.
“The robust training method is the secret sauce of this technique,” How explains.
During flight, the AI-based policy receives information about the robot’s position and converts it into real-time commands controlling factors such as thrust force and torques.
Insect-Like Speed and Agility
Experiments showed that the two-step control system dramatically improved the robot’s performance. The insect-scale machine flew 447 percent faster and achieved a 255 percent increase in acceleration.
It also completed 10 somersaults in only 11 seconds while remaining within about 4 or 5 centimeters of its planned flight path.
“This work demonstrates that soft and microrobots, traditionally limited in speed, can now leverage advanced control algorithms to achieve agility approaching that of natural insects and larger robots, opening up new opportunities for multimodal locomotion,” says Hsiao.
The team also demonstrated a movement known as a saccade. In insects, this involves pitching the body sharply, rapidly moving to a new position, and then pitching in the opposite direction to stop. This quick acceleration and braking can help insects determine their position and maintain clear vision.
“This bio-mimicking flight behavior could help us in the future when we start putting cameras and sensors on board the robot,” Chen says.
Toward Autonomous Flying Microrobots
One major goal for future research is to equip the microrobots with onboard cameras and sensors. That could eventually allow them to fly outdoors without depending on a sophisticated external motion capture system.
The team also plans to investigate whether onboard sensing could help groups of the robots avoid crashing into one another and coordinate their movements while navigating.
“For the micro-robotics community, I hope this paper signals a paradigm shift by showing that we can develop a new control architecture that is high-performing and efficient at the same time,” says Chen.
This research is funded, in part, by the National Science Foundation (NSF), the Office of Naval Research, Air Force Office of Scientific Research, MathWorks, and the Zakhartchenko Fellowship.
